Abhinav Thakare
Engineer + Roboticist, Mechanism Designer, Simulator, Controls Engineer, and Developer
Hi there
I’m Abhinav, a mechanical engineering student at BIT Mesra focused on robotics, mechanism design, and control. I work where free-body diagrams meet solvers — continuum and compliant mechanisms, topology optimisation, and vision-guided closed-loop control. Most recently I’ve been a research intern at IIT Delhi designing a tendon-actuated surgical end-effector.
Before that: piping-systems analysis at L&T, database engineering at Bluestock, and open-source tooling for the ROS ecosystem. All my code lives on GitHub, and you can grab my résumé. I’m always down to talk robotics, so feel free to drop me a line.
Send me a message
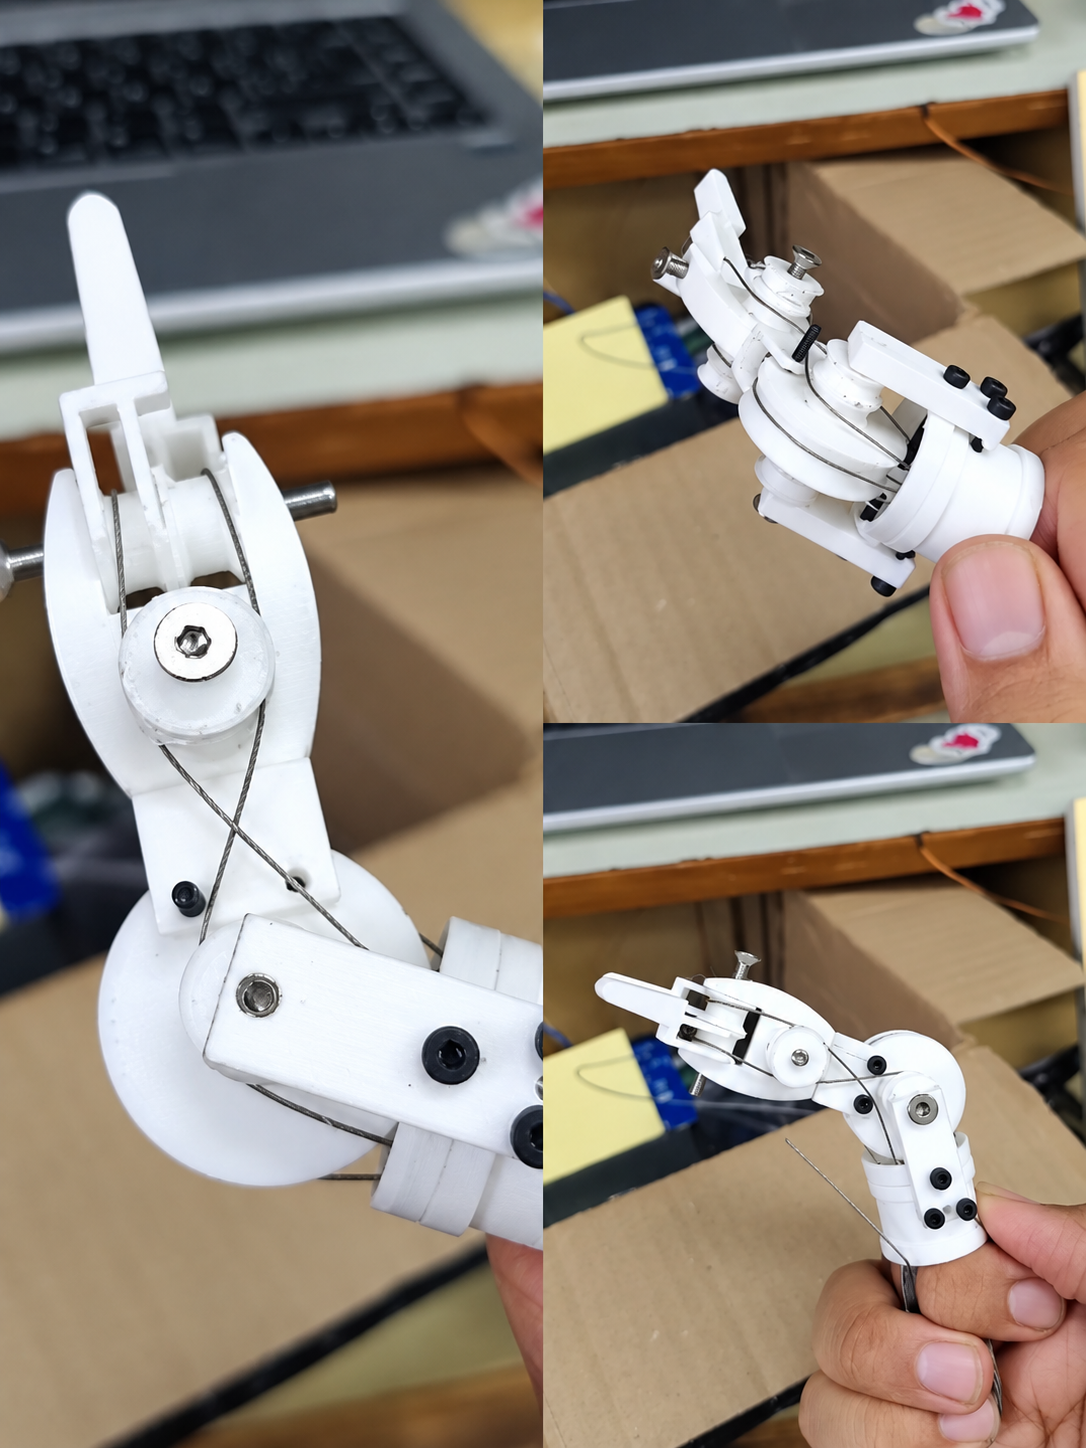
4-DOF surgical end-effector (IIT Delhi)
A low-cost, tendon-actuated branched wrist for minimally-invasive surgery, inspired by the da Vinci EndoWrist — closed-form forward/inverse kinematics, workspace & manipulability analysis, and a Simscape Multibody control pipeline.
Topology-optimised compliant mechanisms
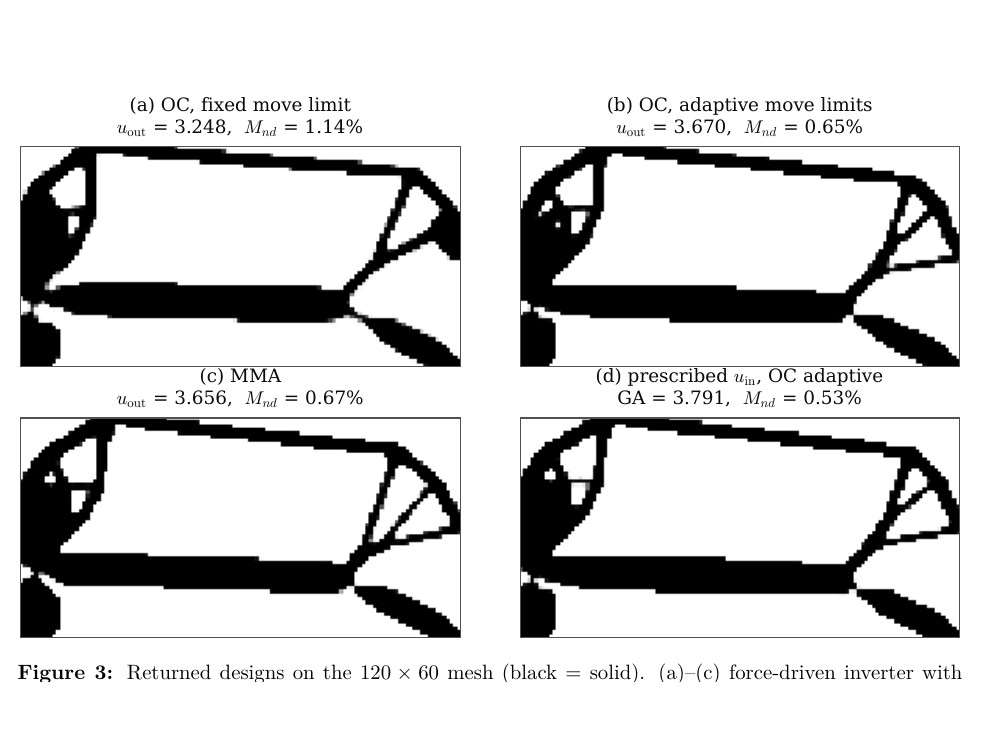
Displacement-amplifying flexures synthesised via SIMP topology optimisation with first-principles adjoint sensitivities — 10× amplification, validated in COMSOL and FDM-printed prototypes (<5% deviation).
Monocular visual odometry
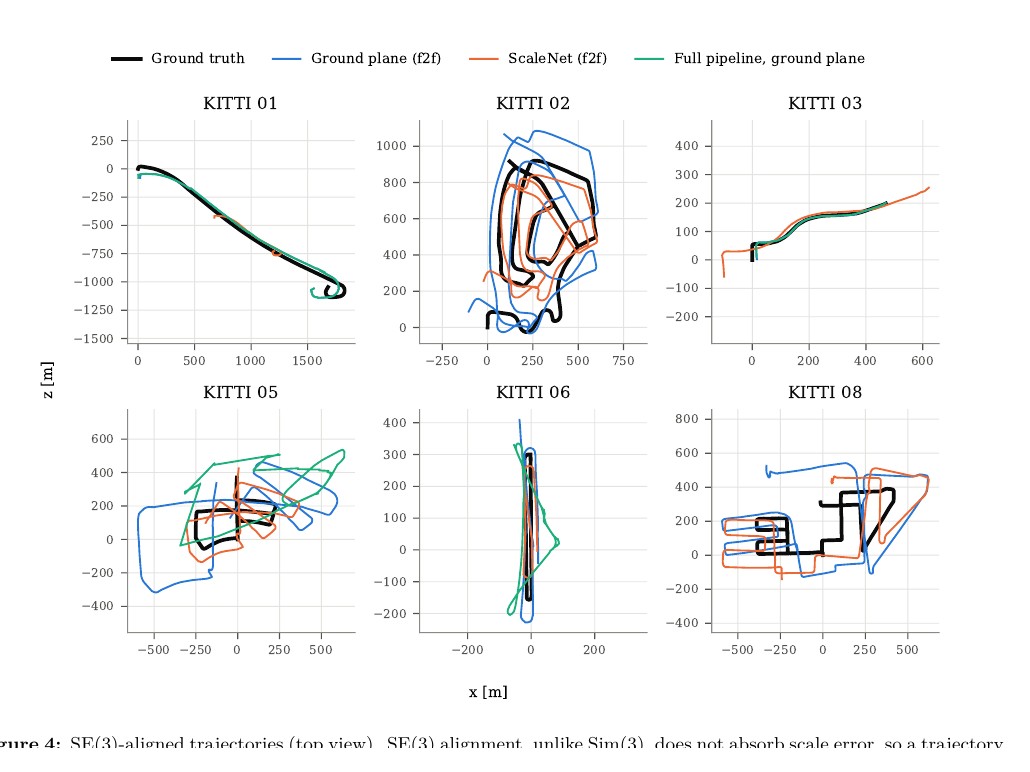
Recovering a camera's trajectory from a single moving camera — feature tracking and essential-matrix decomposition in a lightweight, deep-learning-free pipeline tuned for constrained hardware.
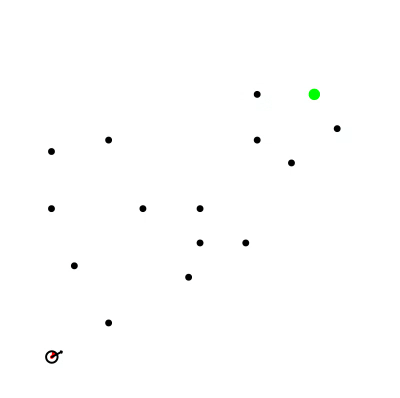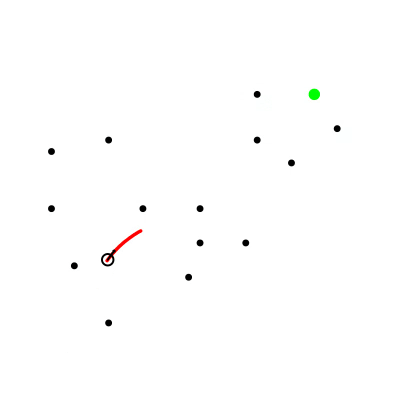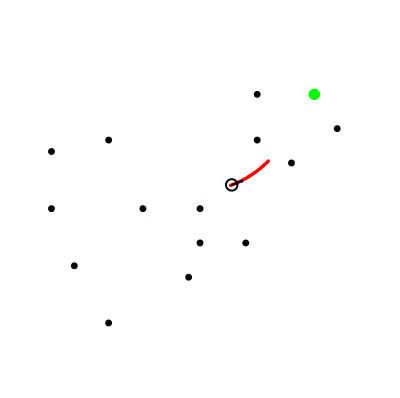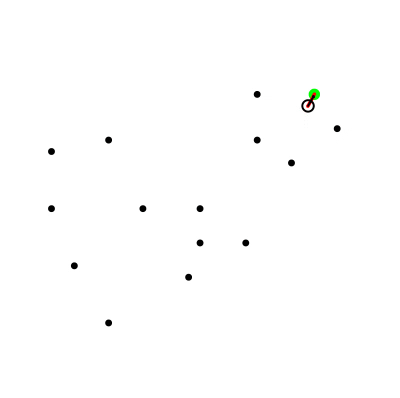
Dynamic Window Approach planner
A real-time local planner for a differential-drive robot — it samples feasible velocity commands inside the dynamic window, rolls each one out, and scores it on heading, obstacle clearance and speed to steer smoothly around obstacles toward the goal. Written in C++.
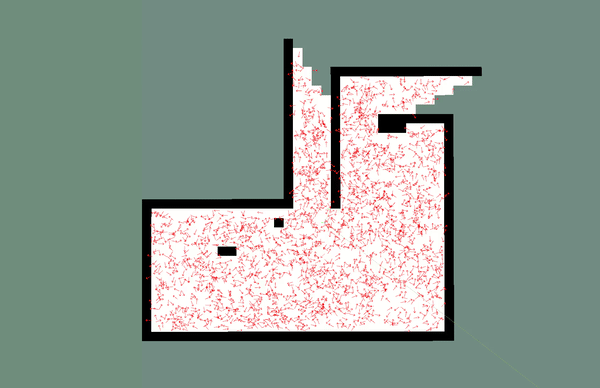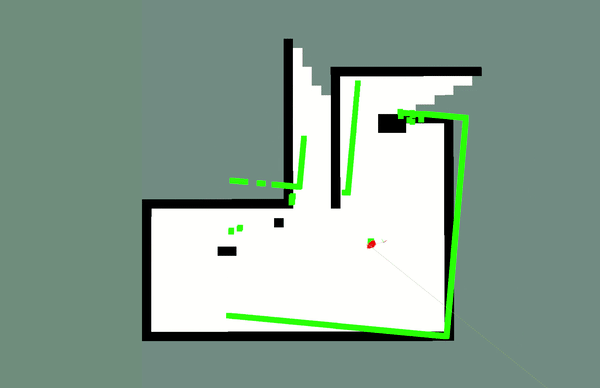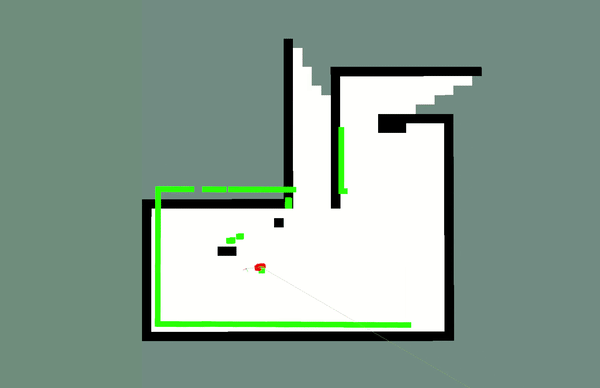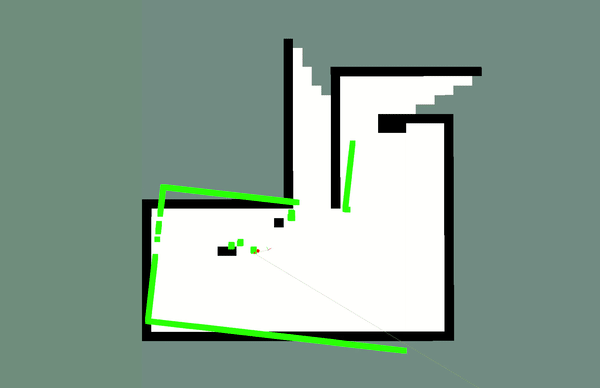
Particle-filter localization (MCL)
Monte Carlo Localization on a known occupancy-grid map — a cloud of particles tracks the robot's pose from odometry and laser scans, resampling toward the high-likelihood hypotheses until it converges on the true pose. Built in C++ with ROS and RViz.

Controlling a tendon-driven continuum robot
Closed-loop control of a soft, continuously-bending manipulator — a Kirchhoff-rod (Elastica) BVP solved with Brent's shooting nested in a Newton-Raphson inverse solver, closed with 30 Hz ArUco tracking for <0.5 mm accuracy. Currently in active development.
Computer Science
Beyond hardware — full-stack platforms, real-time systems, and DevOps I've shipped end to end.
DocOps — multi-agent RAG platform
A self-hosted, multi-agent RAG platform for querying scattered engineering docs — planner/verifier agents, hybrid retrieval (pgvector + BM25, cross-encoder reranked), deployed on Kubernetes with a GitHub Actions CI/CD pipeline.


YouLearn — adaptive learning platform
A full-stack platform turning YouTube playlists into structured, distraction-free courses — Next.js + Prisma/MongoDB, dual-auth (Google OAuth + credentials), 100+ video playlists ingested in under 3s.
Chattyply — real-time chat + DevOps
A MERN real-time chat platform (Socket.IO, sub-100 ms delivery) with a 12-manifest Kubernetes spec, Jenkins CI/CD shipping in under 5 min, and a custom Nginx reverse proxy for WebSocket upgrades.
